Roads, rails and map matching
Question. A straight line is not how people travel. How do I measure distance along roads, find which roads a GPS trace used, and see where flows concentrate?
Use the network functions when a straight-line distance is not a useful proxy for travel. Build the graph once, then reuse it for snapping, route queries, and network-aware measures.
| Term | Meaning |
|---|---|
| Graph | Nodes (road connectors) joined by edges (road segments with a length, speed and class). |
| Snapping | Assigning a point to its nearest node, within a maximum distance. |
| Map matching | Choosing, for every GPS fix of a trace, the most likely road segment. |
Route flow (the library's od_desire_lines) |
Flow between origins and destinations, added up on the road segments of each pair's fastest route. A desire line in the strict sense is the straight line between the origin and the destination. |
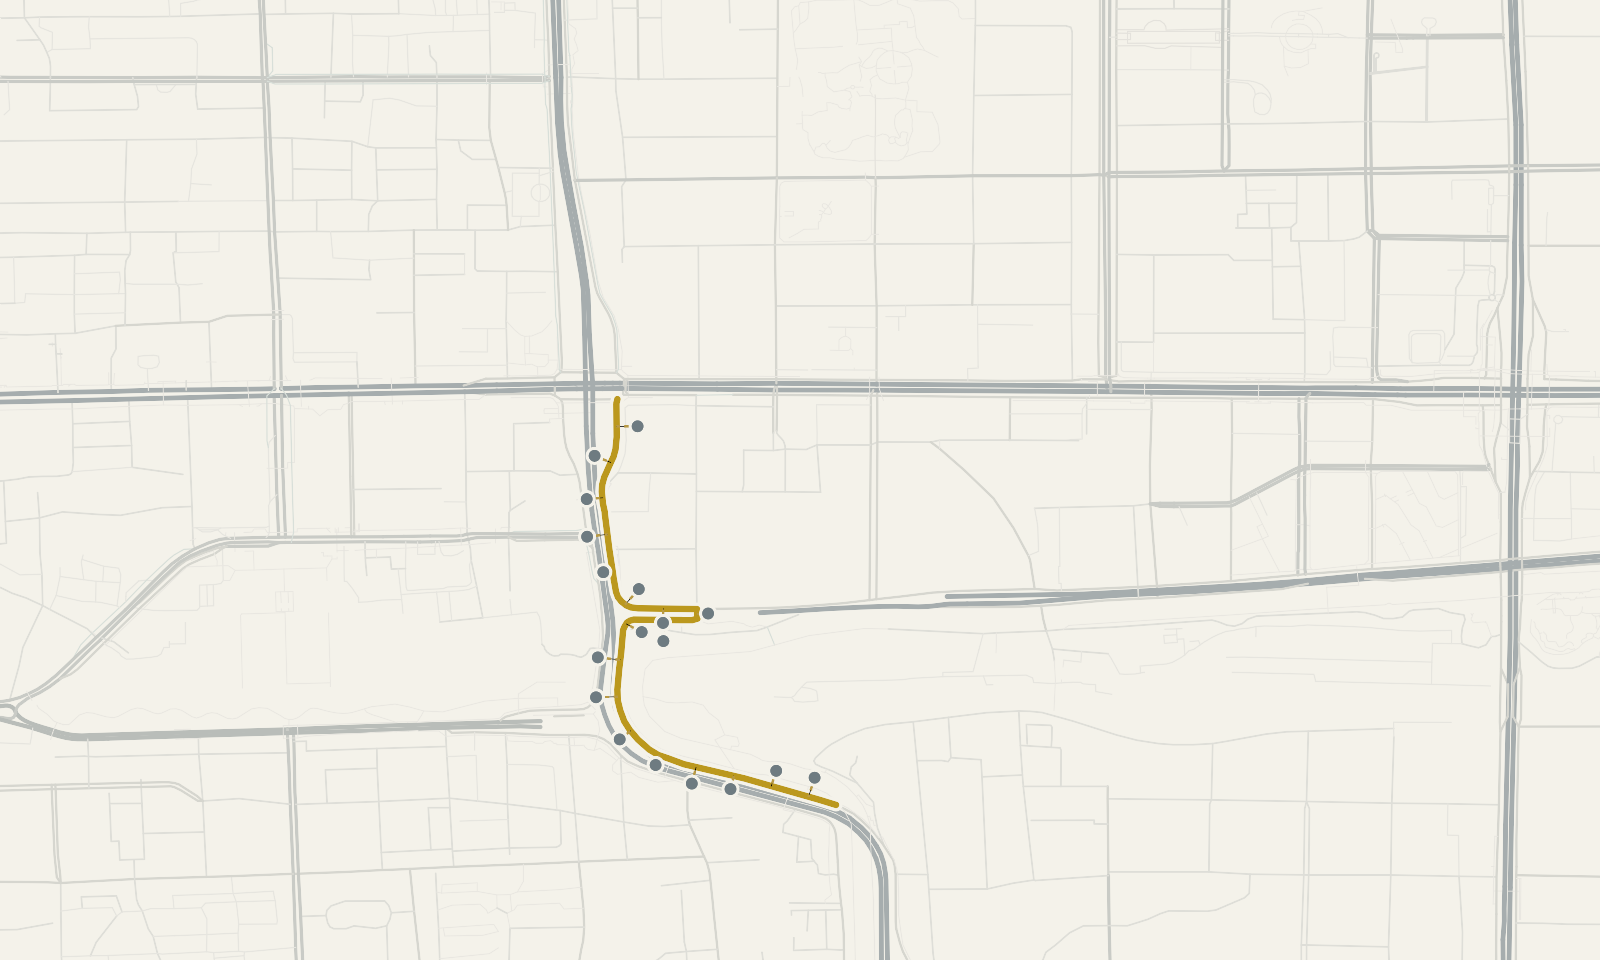
Road geometry from the Beijing OpenStreetMap extract; GPS observations are illustrative. © OpenStreetMap contributors.
Run it on real data in Road networks: matching, routing and route flows, which fetches a road network, matches a GPS trace, compares road and straight-line distance and accumulates flows on roads.
Build the graph once and reuse it; do not fetch or prepare it once per trajectory.
Snapping returns -1 for a point outside the chosen threshold, and
network-aware distance measures fall back to Haversine when an endpoint is
unsnapped or disconnected.
match_trajectory returns one result row per input observation with matched
edge information, projected coordinates, status, and a score. It processes
users independently and splits tracks at invalid observations or large time
gaps. Its current edge projection uses connector-to-connector segments, so
inspect results carefully on curved roads.
Optional dependencies and data access
Fetching Overture networks requires the network extra and access to the
requested Overture release. Save the node/edge tables with
build_road_graph when repeatedly analysing the same area.
See the network reference for Arrow return types, route geometry, OD desire lines, and rail support.
Related API
match_trajectory ·
build_road_graph ·
fetch_road_network ·
snap_locations_to_graph ·
RoadNetwork ·
od_desire_lines ·
build_rail_graph